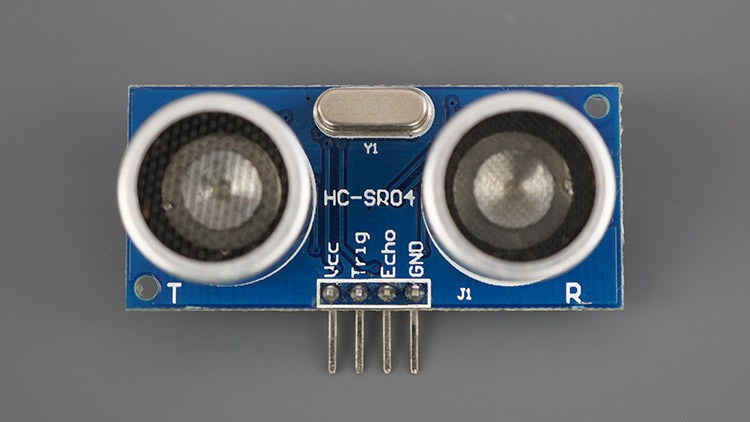
Working with STM32 and ultrasonic: using timer and interrupt to measure the distance
In the previous guide(here), we looked at the operation principle of how ultrasonic works and we used very crude code to measure the distance.…
509 articles · Page 49 of 51
In the previous guide(here), we looked at the operation principle of how ultrasonic works and we used very crude code to measure the distance.…
In the previous guide (here), we discussed how to send a single character using SPI in polling mode. This method will decrease the CPU…
In this guide, we shall discuss what is SPI and how transmit single byte over SPI. In this guide, we will cover the following:…
In this guide, we shall use registers to change the core frequency from default 16MHz to 100MHz (maximum for F411RE). We shall use both…
In pervious guides, we took look how to send string using DMA (here), and how to receive characters using interrupt(here). In this guide, we…
In previous guides, we looked at TIM2 of STM32 to generate delay, interrupts, PWM and how to use PWM to fade LED and control…
In this guide, we shall discuss what is I2C and how to make an i2c bus scanner to scan the slave devices that connected…
In the pervious part (from here), we took a look how to send string in UART using polling mode. In polling mode, we forced…
In pervious PWM guide (here), discussed how to use TIM2 of STM32F411 to generate 2 PWM signals to fade 2 LEDs. In this guide,…
In pervious two guides we took look at how to use systick timer to blink an led without using delay (here) and how to…